Chief Technology Officer · Co-Founder
Shenzhen Mifan Intelligent Technology Development Co., Ltd.
Embodied AI · ROV Autonomous Systems · SLAM · Hong Kong / Macau / Shenzhen
To know what lies beyond sight.
Multimodal perception, SLAM, embodied decision-making, and closed-loop control for reliable autonomy underwater and on land.
Shenzhen Mifan Intelligent Technology Development Co., Ltd.
Asia Best Partner International Freight Forwarding Co., Ltd.
Multimodal perception · Localisation · Decision · Closed-loop control
Read the trace. Answer with action.
Work spanning multimodal perception, localisation, embodied decision-making, and closed-loop control in underwater and terrestrial environments.
Embodied agents, underwater autonomy, multimodal reasoning, acoustic perception, and real-world deployment.
Sonar and visual SLAM, sensor fusion, navigation, manipulation, embedded control, and model deployment.
Agentic AI products, multi-agent workflows, operational platforms, and technical strategy.
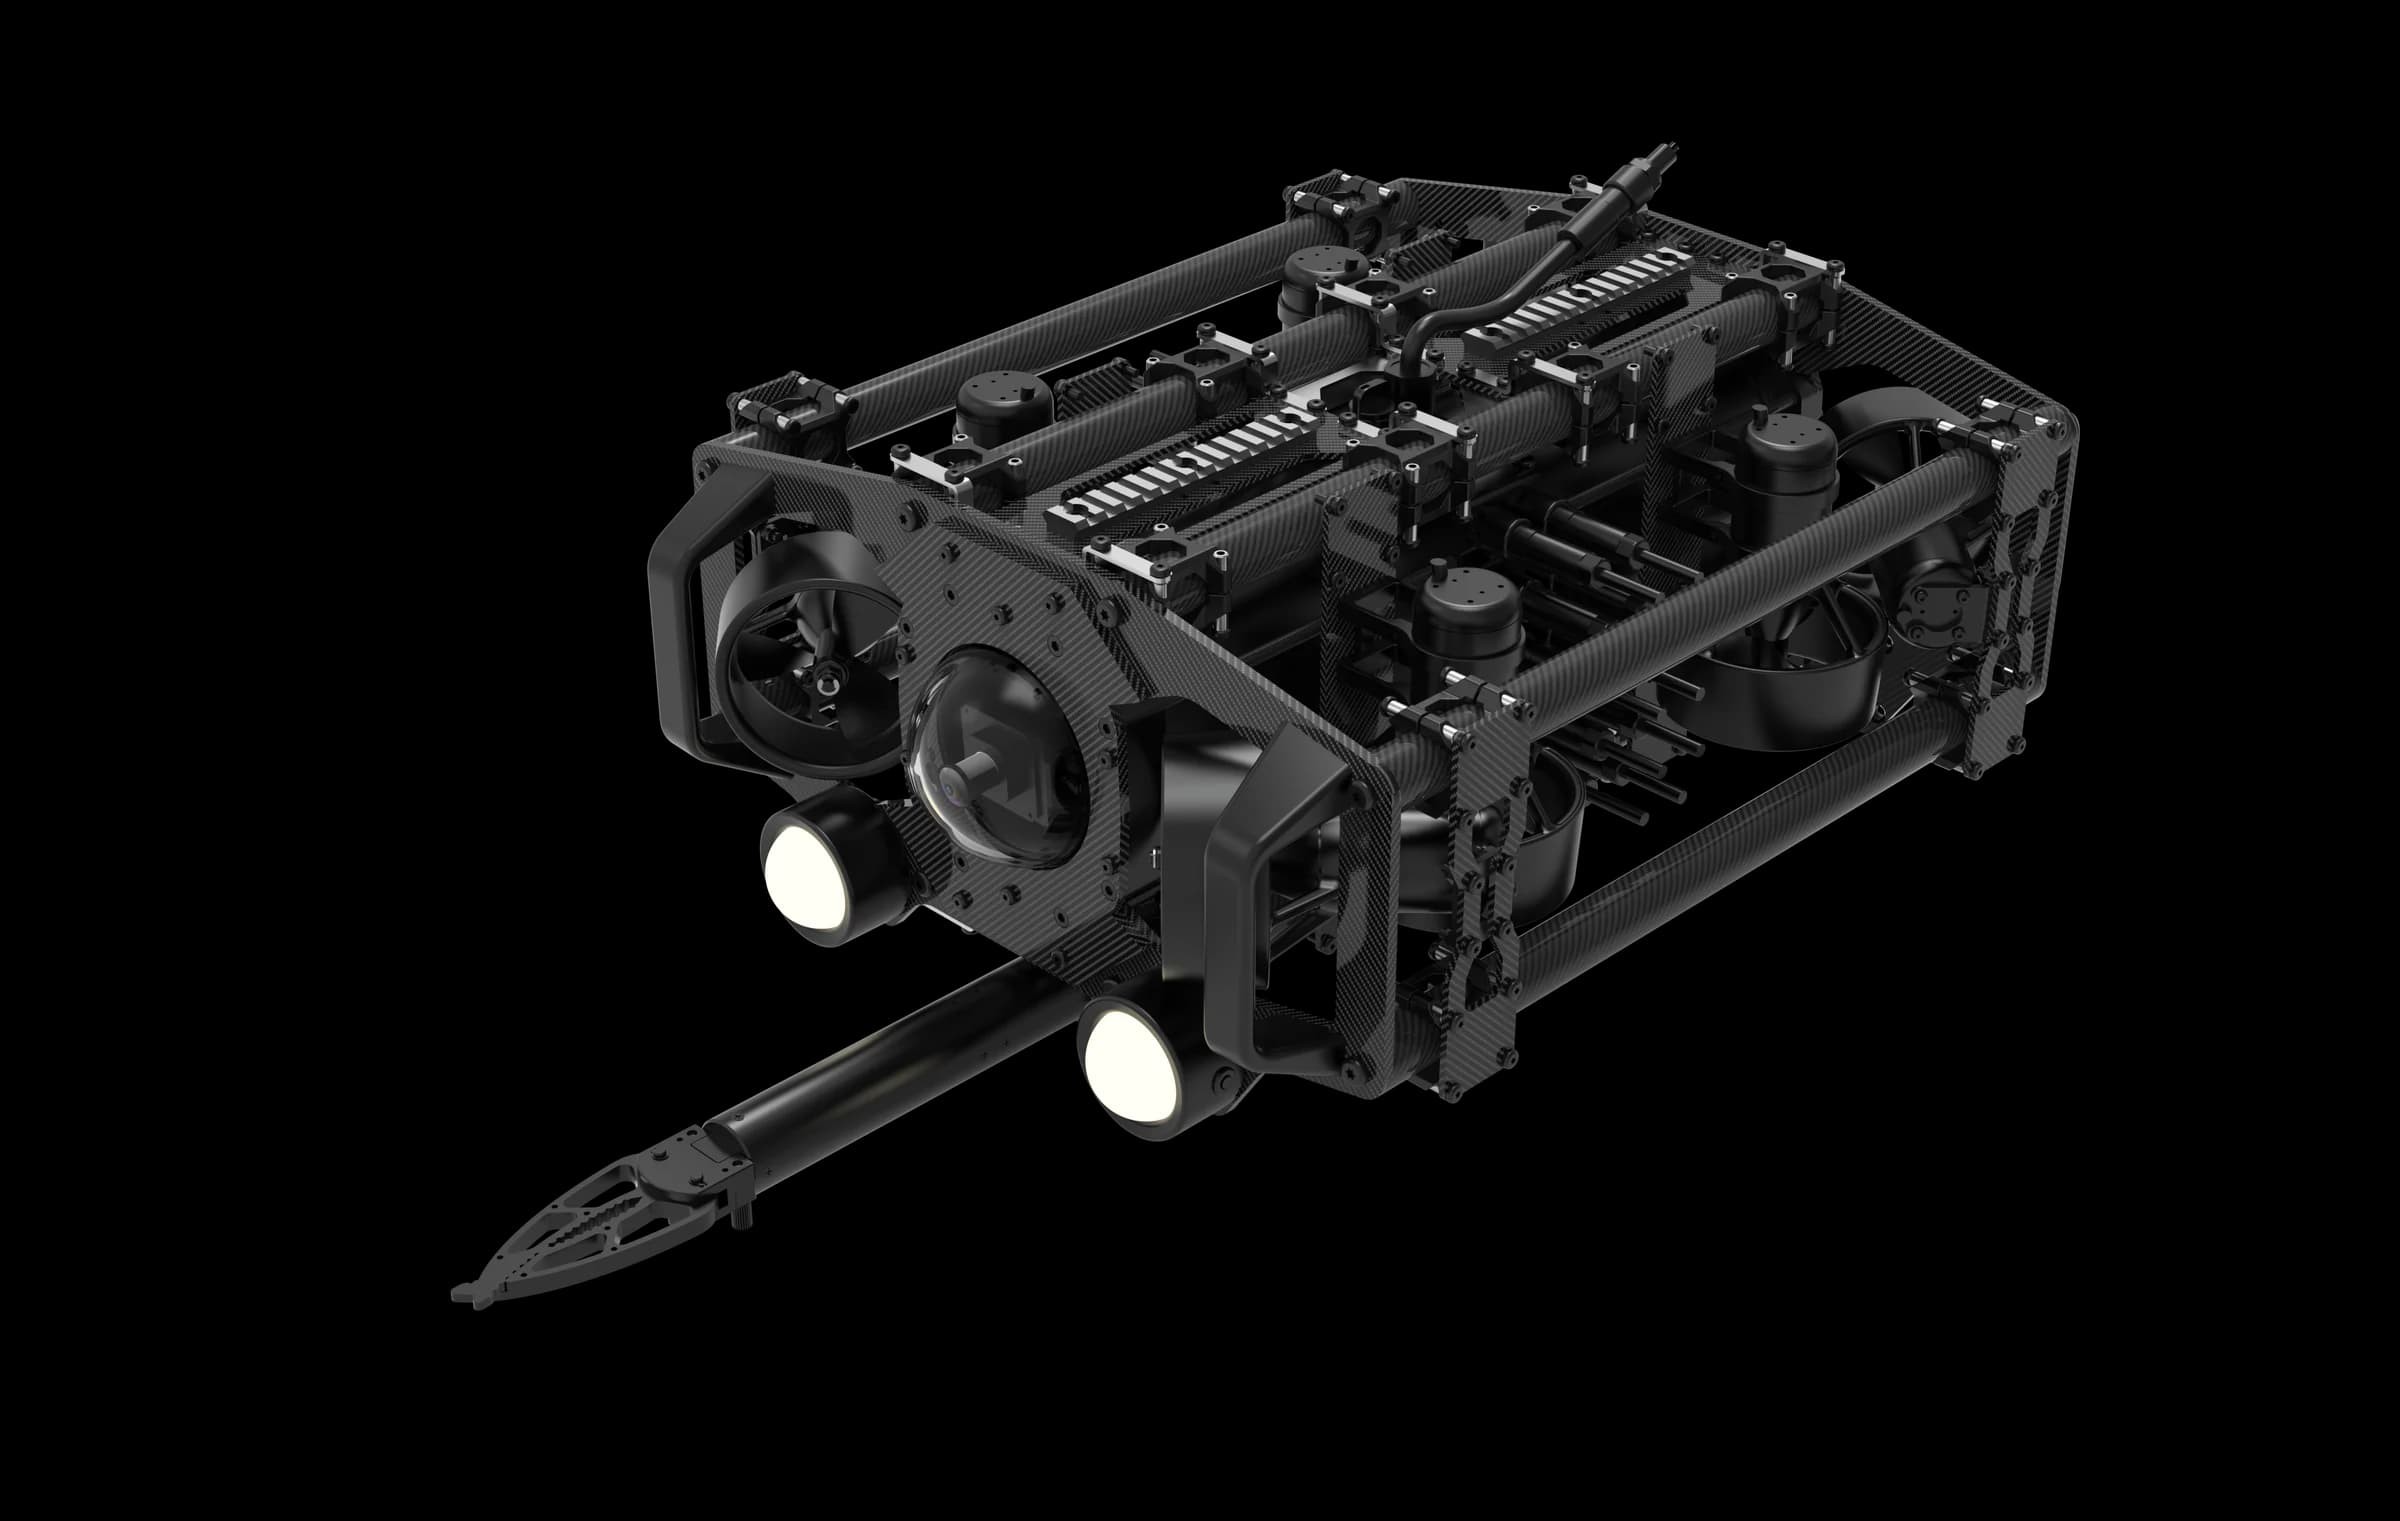
ROV · Embodied Agents · SLAM
Research on underwater perception, localisation, task planning, and motion control under low visibility and constrained communication.
How can an underwater robot sustain situational awareness and useful action under weak visibility, uncertain dynamics, and constrained communication?
How can an agent ground long-horizon intent in tools, physical constraints, feedback, and recoverable execution?
How can sparse, noisy acoustic returns become stable geometry and localisation in visually degraded environments?
Mobile manipulation · Agent workflows · Field perception
Work in mobile manipulation, freight workflow automation, and debris-flow monitoring, each tied to a research, product, or deployment record.
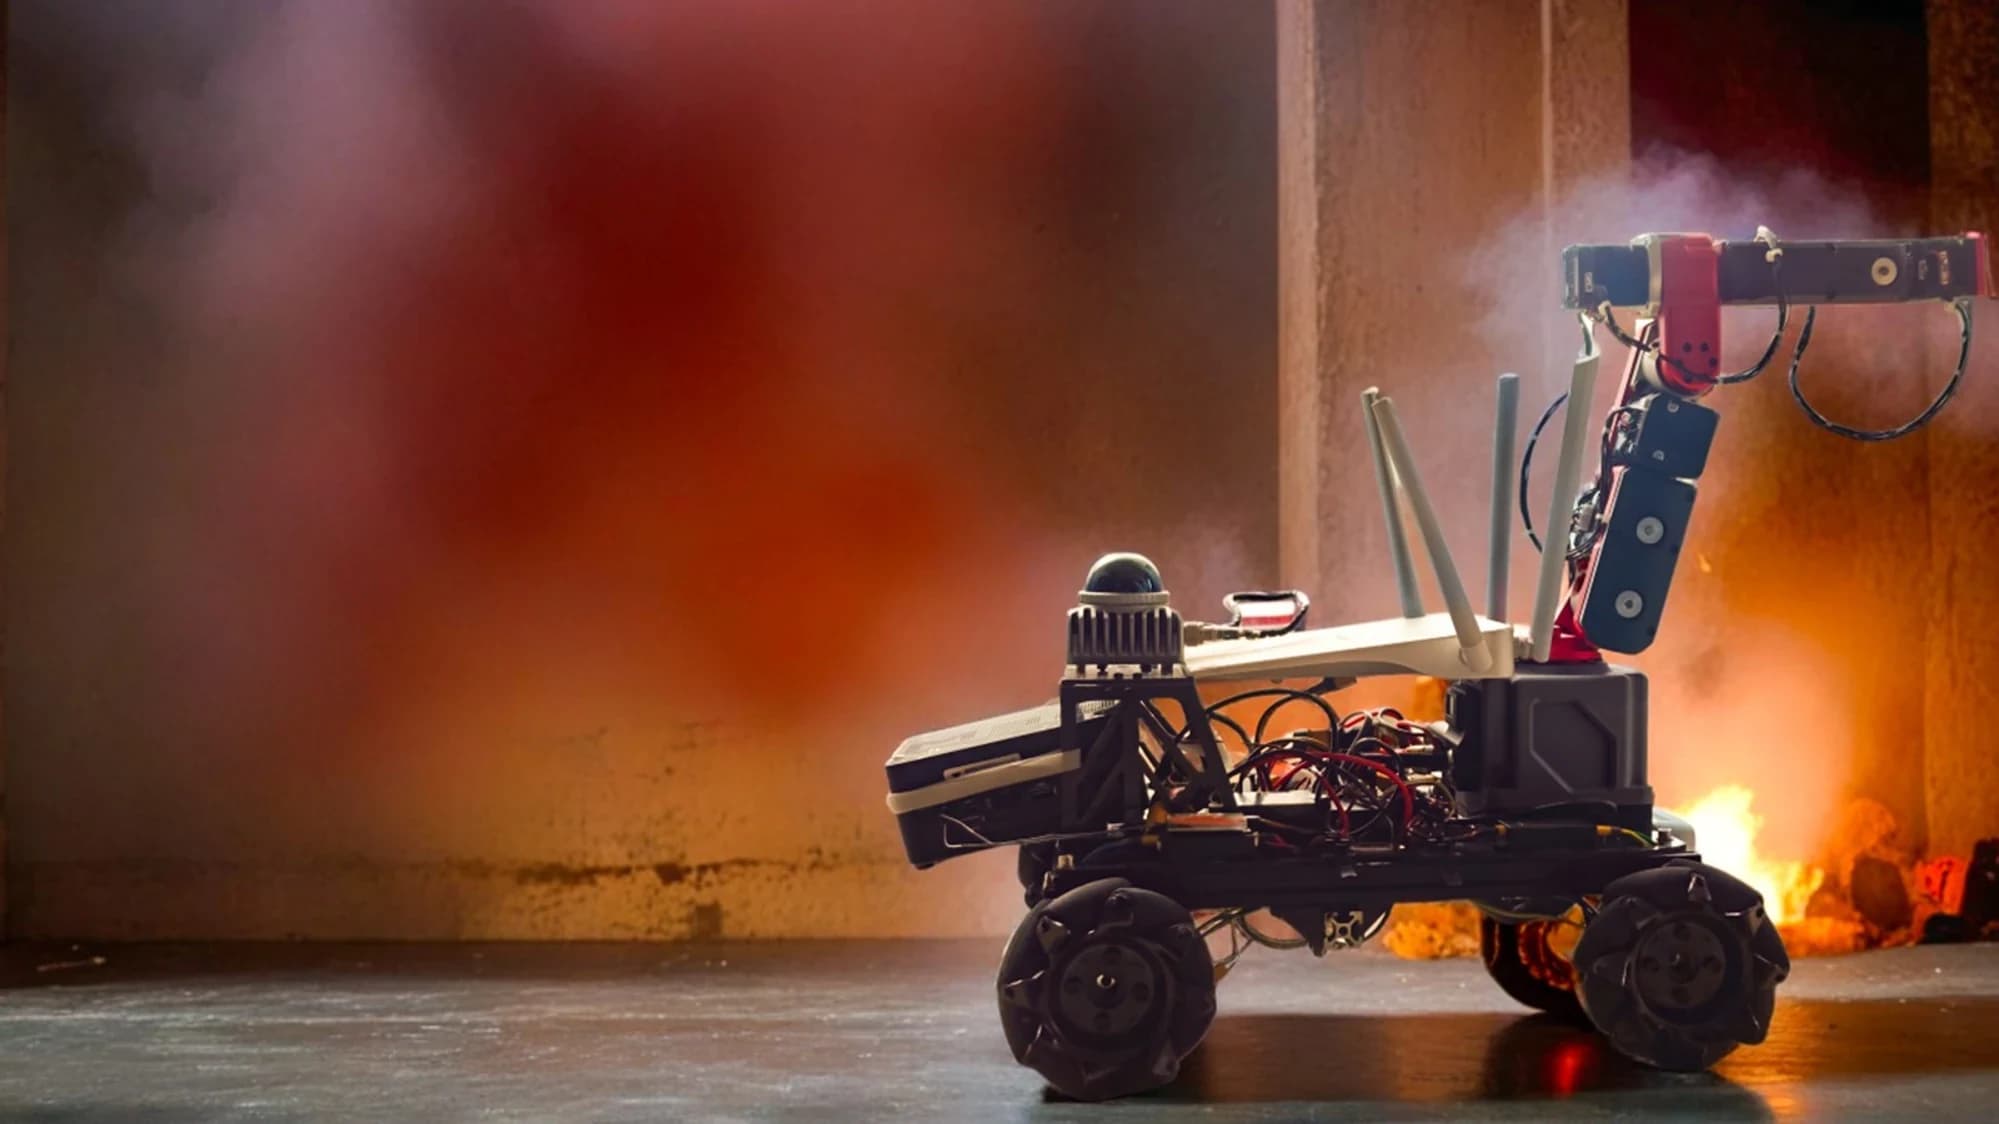
Perception, mobility, and manipulation under a staged field condition.
Omnidirectional chassis motion test.
Live point-cloud mapping in RViz.
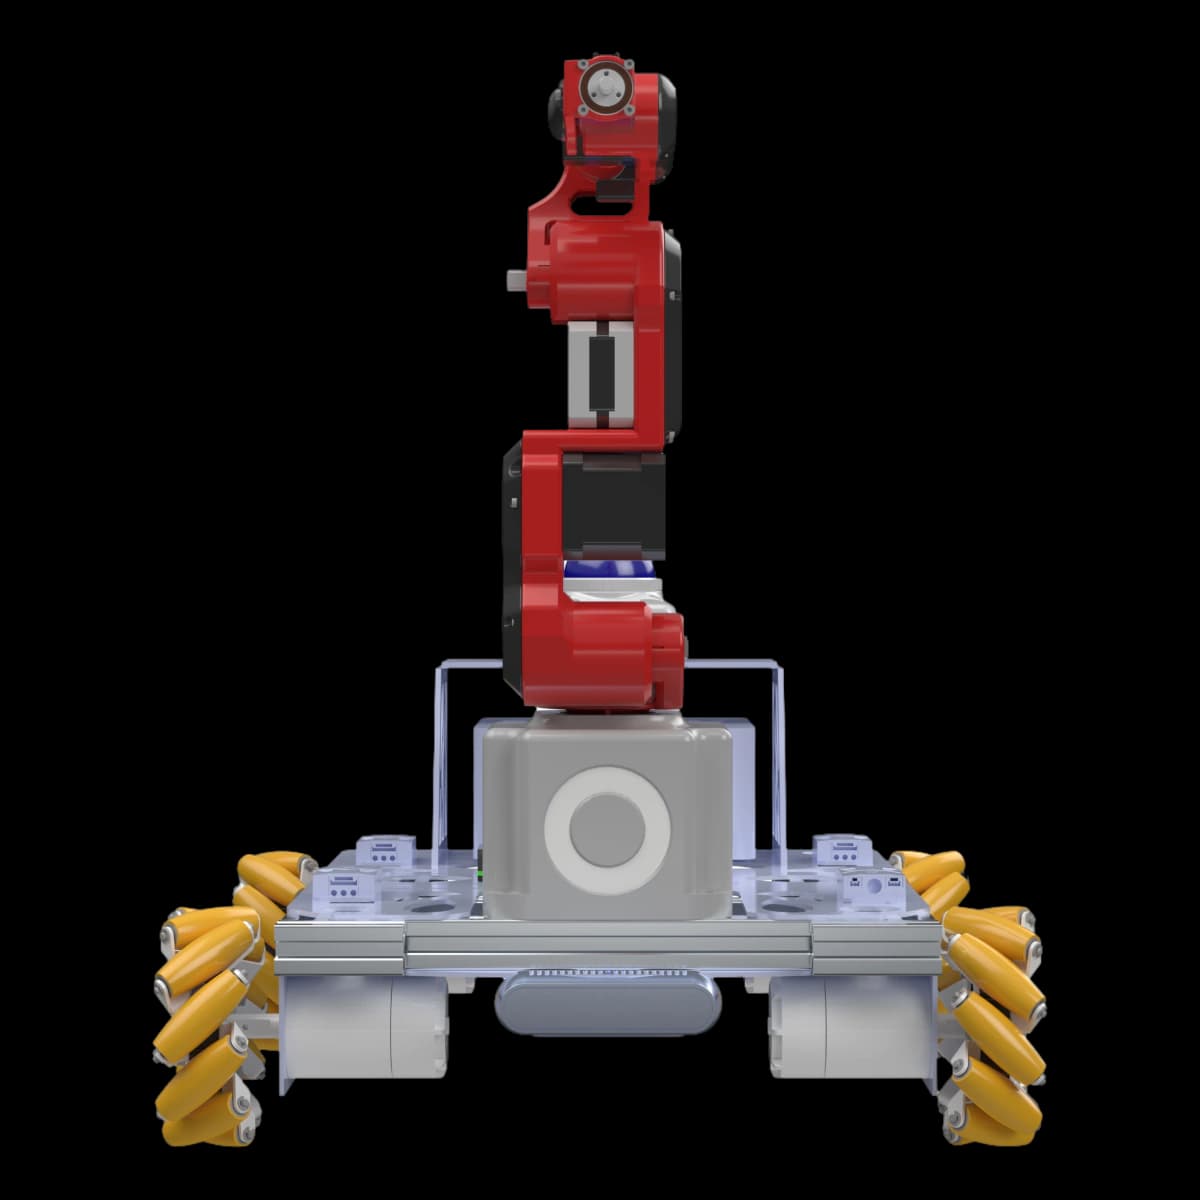
Front view of the mobile manipulation system.
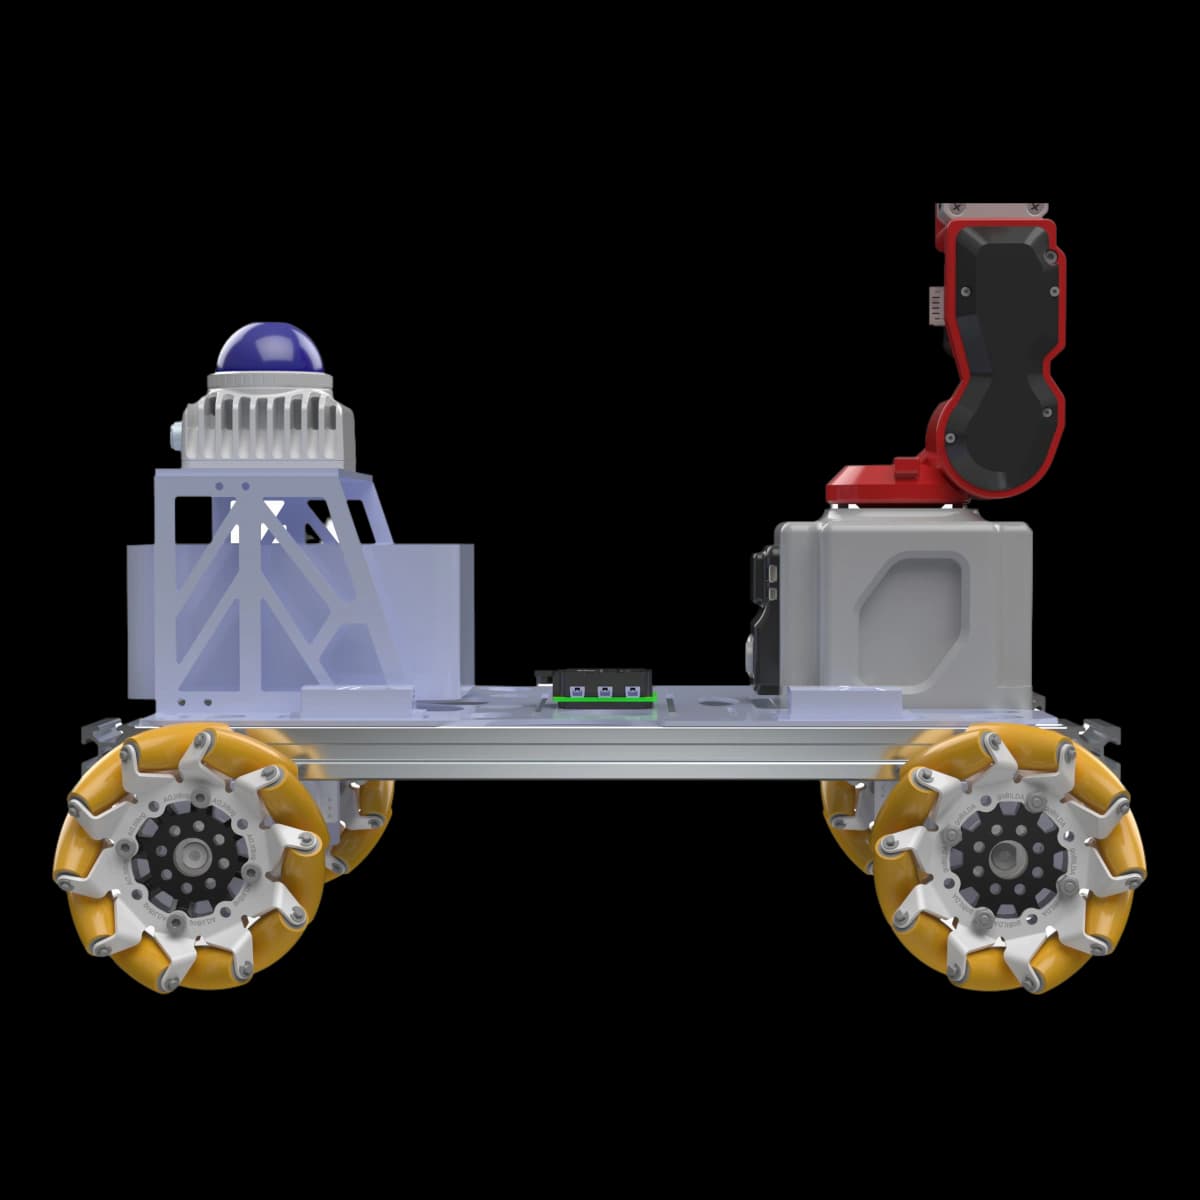
Chassis, sensing assembly, and drive layout.
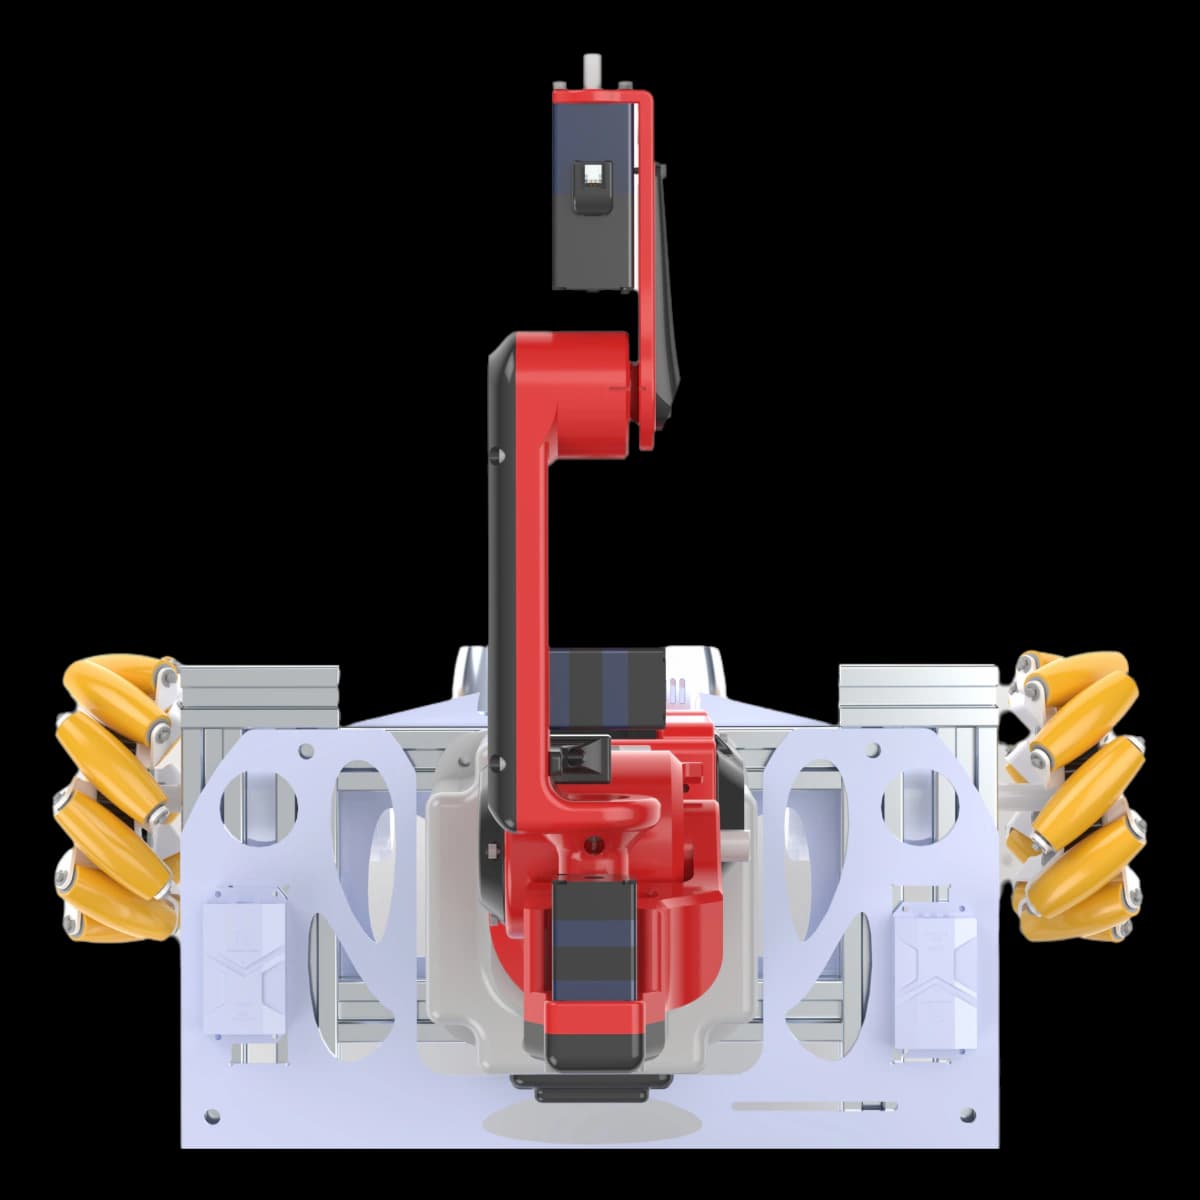
Manipulator mounting and component arrangement.
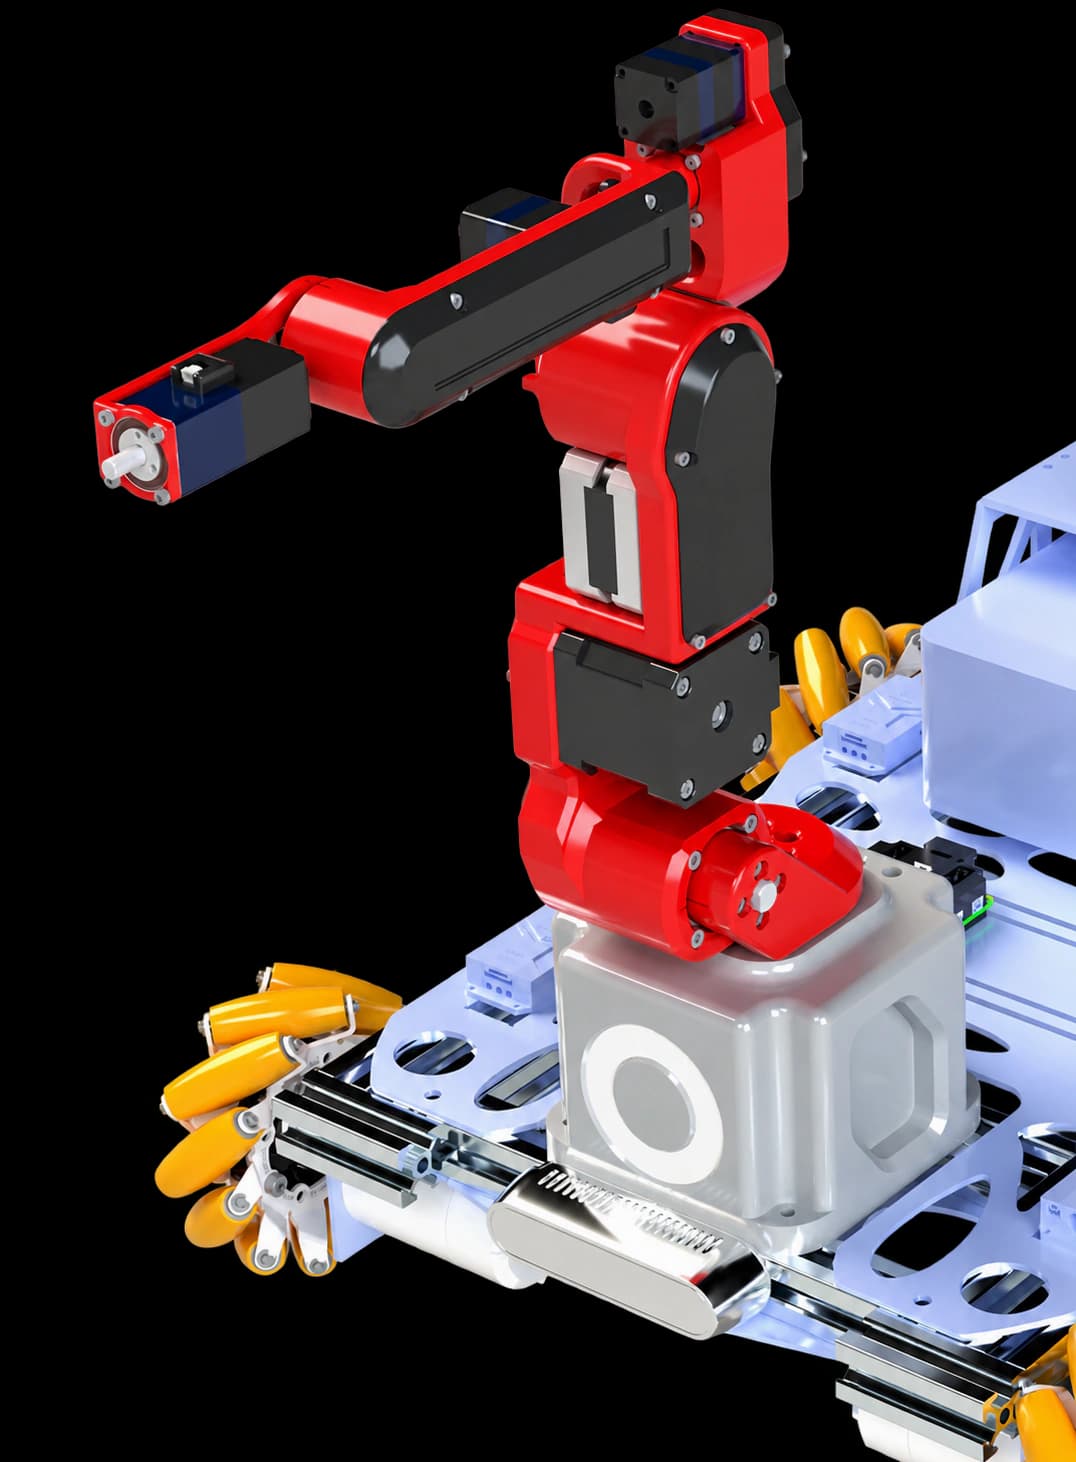
Joint architecture and mounting structure.
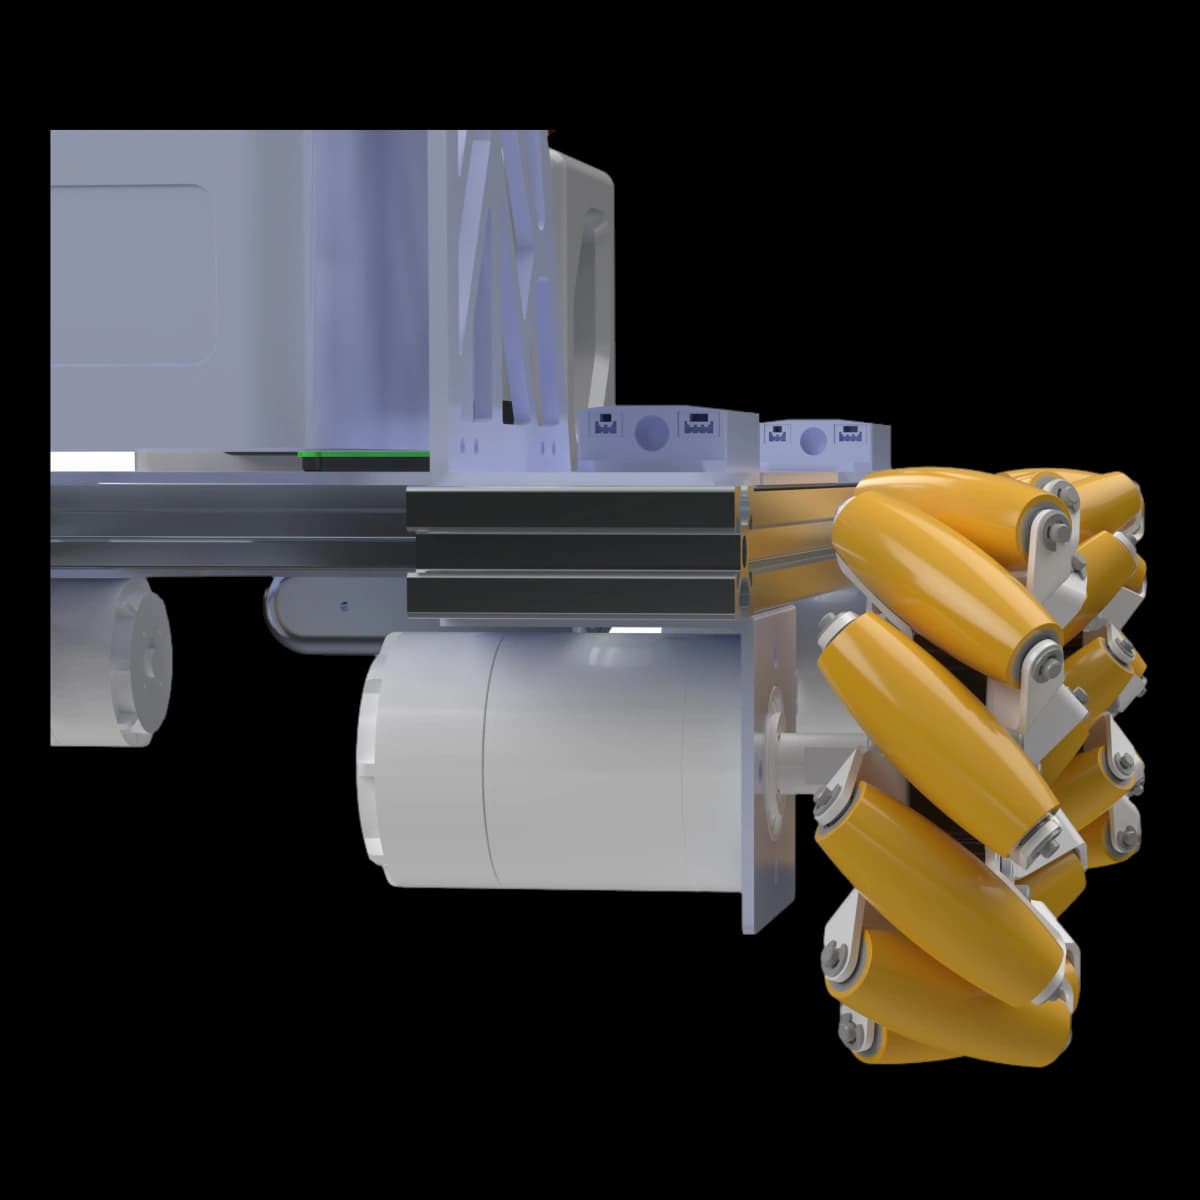
Wheel geometry and drive assembly.
Mobile manipulation
Where intent finds motion.
Agentic workflow automation
Many threads, woven into one flow.
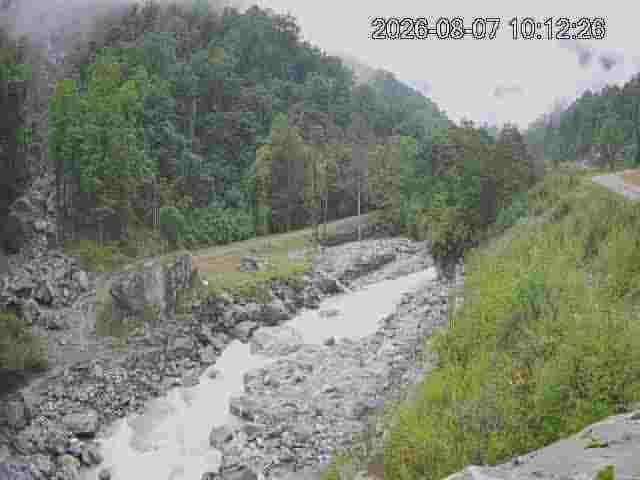 Mountain channel
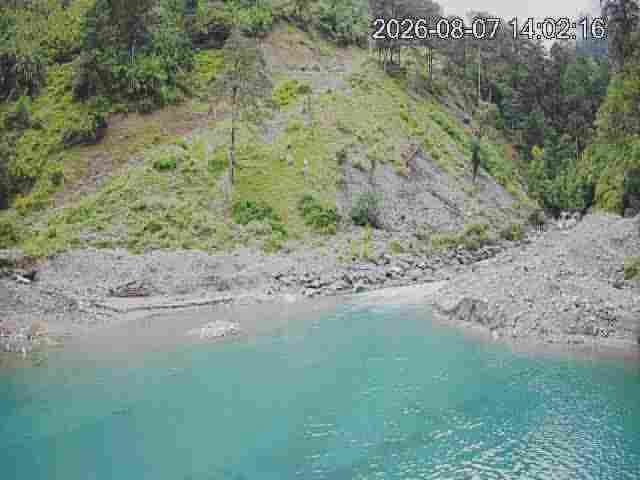 River slope
Field perception & warning
Reading the mountain before it moves.
System trajectory
A trajectory through robot fabrication, indoor localisation, touch-free interaction, embodied intelligence, and autonomous systems research.
FTC operator, structural design lead, and business liaison. Designed and fabricated robots with SolidWorks, laser cutting, 3D printing, and CNC.
Led ShopChain's fusion of UWB beacons and QR codes for indoor positioning; awarded the PolyU Student Entrepreneurial Proof-of-Concept Fund.
Built a touch-free operation system using Arduino, ESP32, CAD, and 3D printing; received 1st Runner-up in the PolyU Best Project Award Competition.
Sentra One connected LLM/VLA-style task planning with navigation, perception, and manipulation; accepted at EVS39.
Beginning doctoral research at The Hong Kong Polytechnic University and the University of Macau, focused on embodied AI and robotics.
Papers · Deployment · Recognition · Appointments
Publications, software, deployments, recognition, and appointments.
39th Electric Vehicle Symposium & Exhibition, Long Beach, California, June 2026.
World Electric Vehicle Journal Special Issue EVS39; recommended following EVS39 with APC waived.
Submitted to the Copyright Protection Centre of China, May 2026.
Shenzhen Mifan Intelligent Technology Development Co., Ltd.
Asia Best Partner International Freight Forwarding Co., Ltd.
Chengdu Institute of Care-Life / Institute of Mountain Hazards and Environment, Chinese Academy of Sciences
Inspur Group
Autonomous systems stack
Autonomous robotics, agent systems, machine perception, embedded control, and engineering implementation.
LLM application harnesses, multi-agent orchestration, tool calling, prompt engineering, and RAG workflows.
LogiAuto / enterprise AI systemsAGV and ROV system thinking, SLAM, localisation, navigation, depth sensing, and mobile manipulation.
Sentra One / foundation for underwater autonomyObject detection, segmentation, YOLO pipelines, optimisation, and field deployment.
Debris-flow early warningSTM32, ESP32, Arduino, sensor interfaces, low-level actuation, and wireless charging modules.
Sentra One / Touch-Free / PC3Python, C++, Java, MySQL, Linux, ROS, Git, SolidWorks, AutoCAD, fabrication, and circuit assembly.
Across research and product systemsResearch · Engineering · Deployment
For research and engineering collaboration in embodied intelligence, ROVs, and autonomous systems.
walter-hh.yu@polyu.edu.hk